About Me
Hello, I am a Mechanical Engineering student at Texas A&M University with a passion for bridging the gap between hardware design and autonomous intelligence. I have a background ranging from structural engineering and large-scale industrial project management to robotics research. I aim to work at the intersection of mechanical systems and software, currently contributing to autonomous drone path planning and robotic rover development.
Projects
T.U.R.T.L.E Robotics Rover
Designed rover frames, retractable clasps, and custom components in SOLIDWORKS; manufactured parts via machining and 3D printing within tolerance requirements.

Experience
Engineering Operations & Design Intern
Shangrila Engineers
- Applied AISC standards and LRFD/ASD methodologies to calculate beam moments, shear forces, reactions, and deflection margins, ensuring structural compliance for complex project designs.
- Orchestrated corporate engineering compliance across all 50 state jurisdictions by managing Firm Certificates of Authorization and tracking state-specific firm registration mandates.
- Administered project control systems by managing integrated cost master spreadsheets and auditing internal time-sheet tracking software to optimize engineering labor allocation.
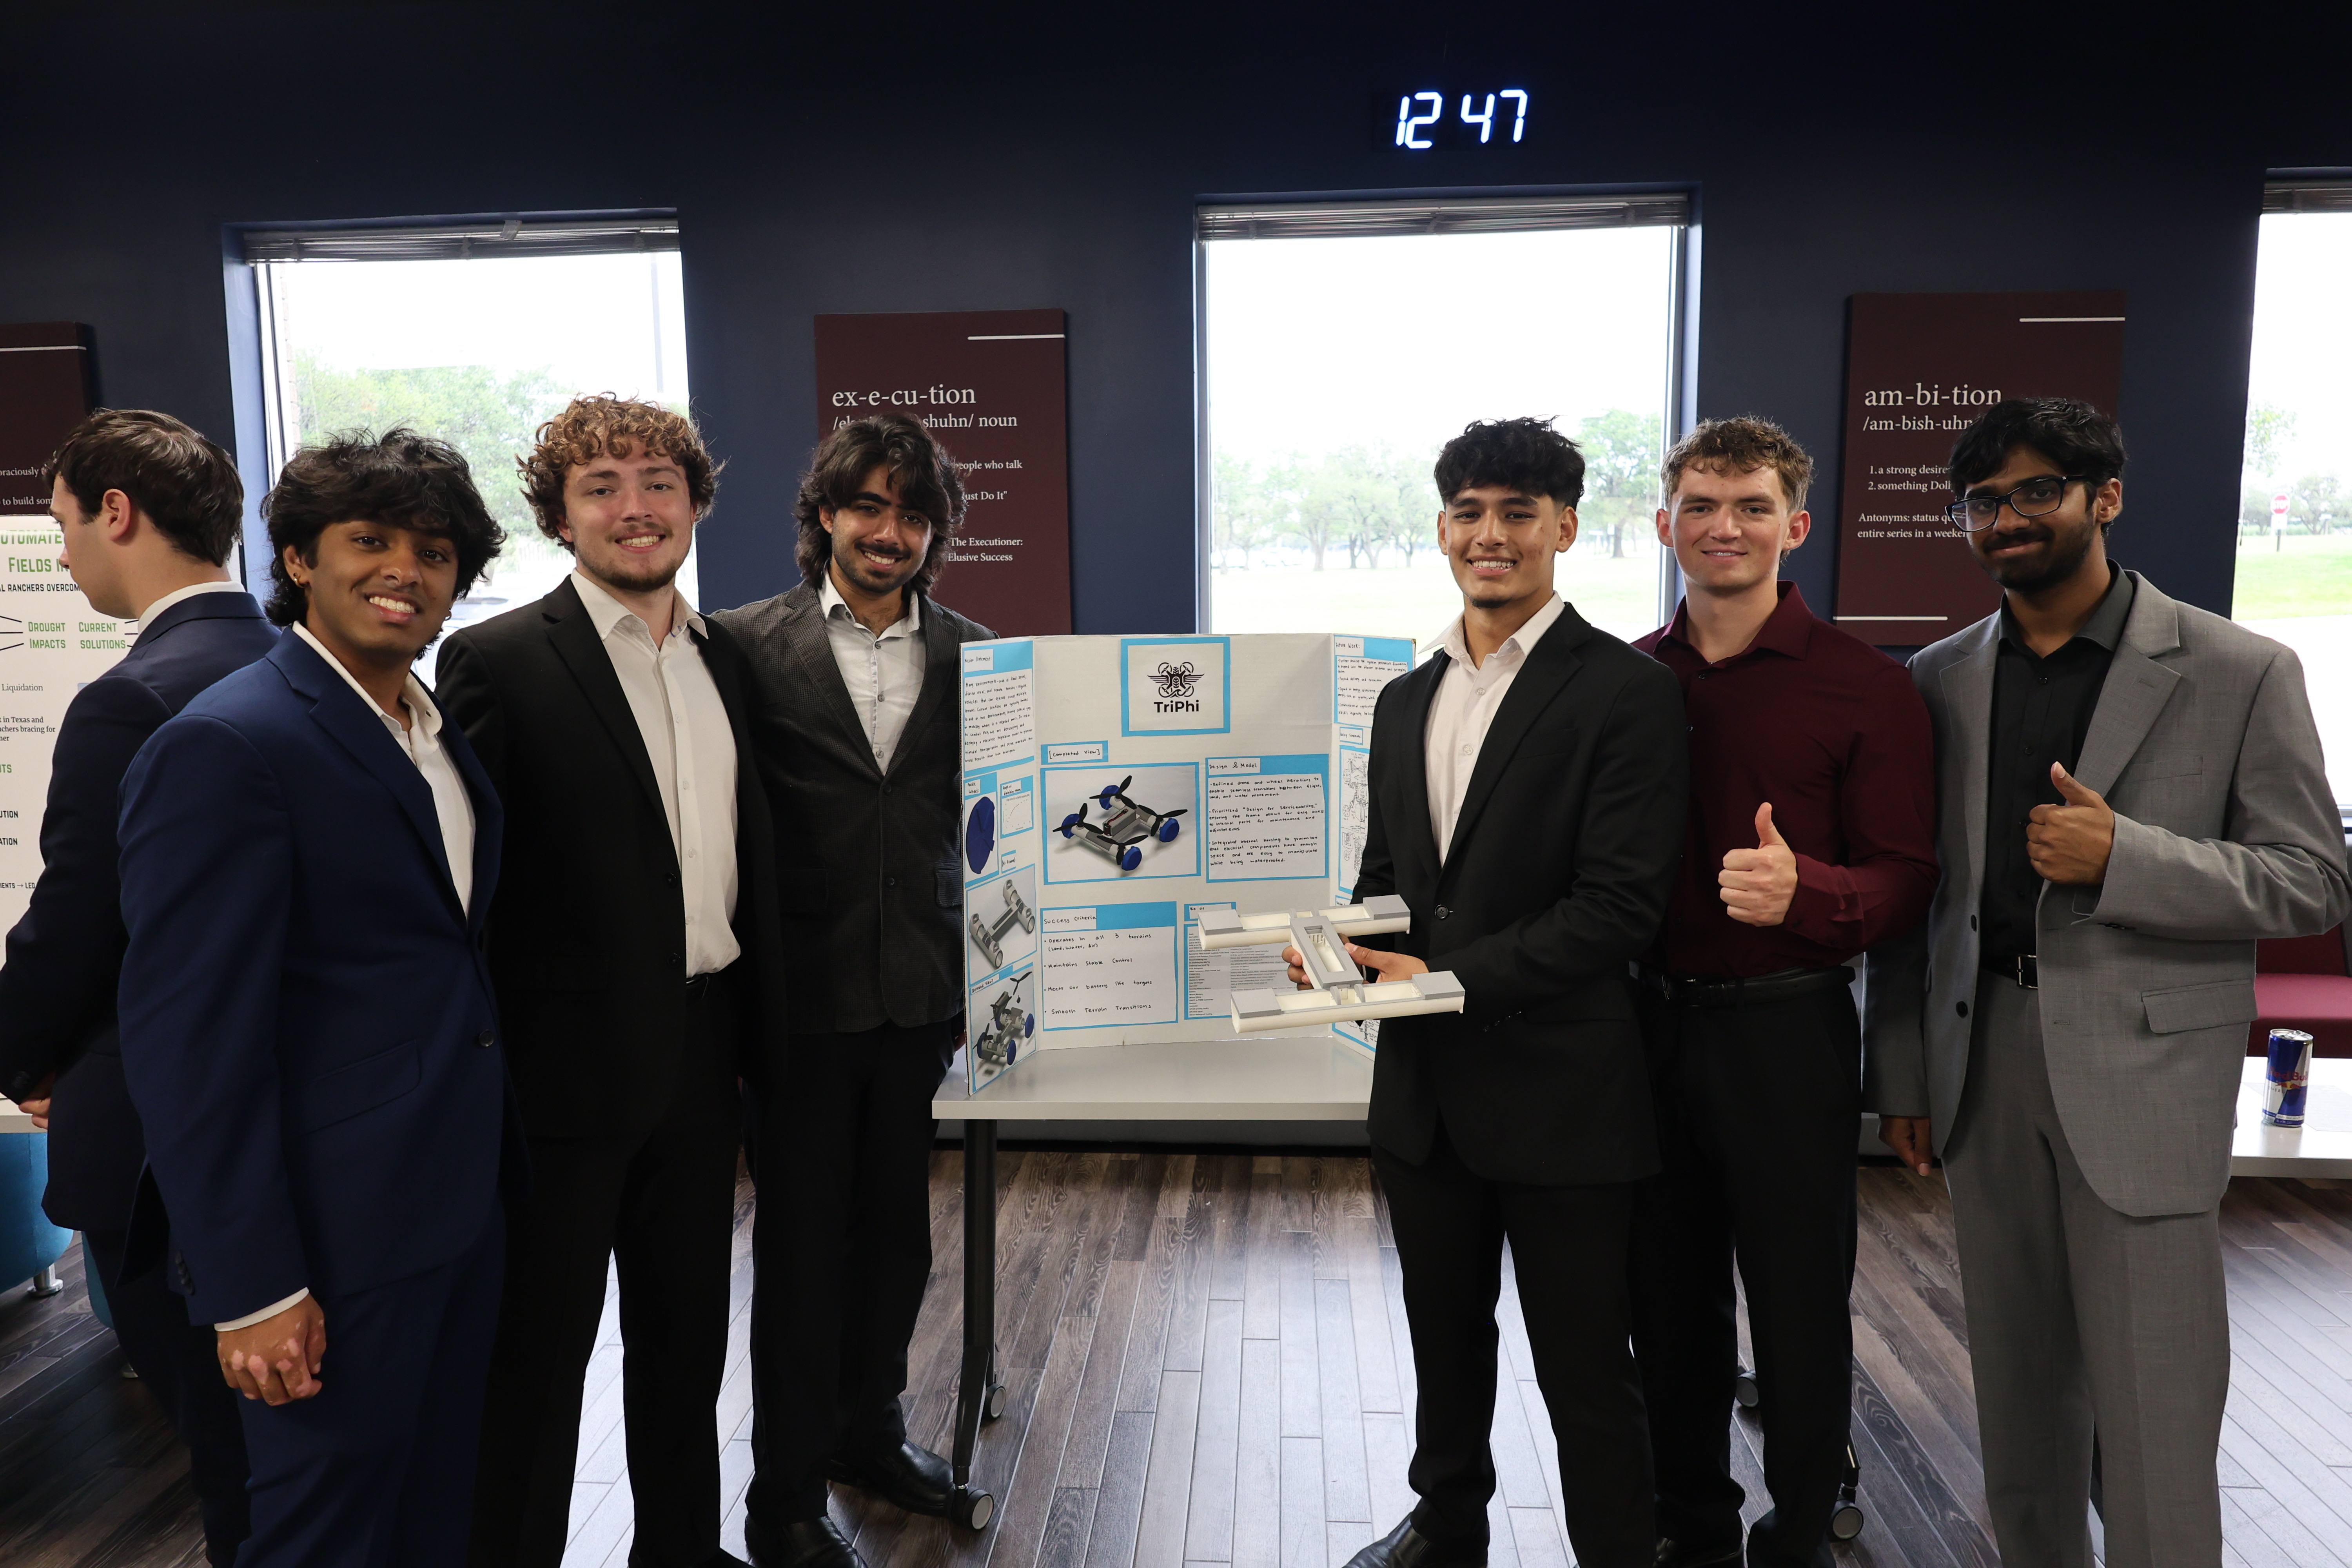
Founder / Team Lead – Triphibian Multi-Terrain Rover
Aggies Create (University Project Sponsorship)
- Secured $1,000+ in funding per semester through a competitive design pitch series by pitching a rover capable of air, land, and water operation.
- Leading 5 diverse engineers and managing project budget to coordinate the initial 3D printed prototype development series with emphasis on propulsion, mobility, and control subsystems.

Undergraduate Researcher – Autonomous Drone
Texas A&M Vertical Flight Society
- Researched and implemented autonomous eVTOL path-planning algorithms (RRT) using Python, ROS2, and Gazebo, identifying performance bottlenecks and implementing optimizations to improve runtime performance.
- Ported autonomy algorithms from simulation to a physical rover by restructuring code to JSON-based configuration, allowing real-time implementation of integrated measurement units, sensors, and testing.
Project Management Intern
Sintek North America
- Supported the construction of a 600,000-ton annual capacity clinker grinding plant using Navisworks and Trimble to model various assemblies via PFDs and P&ID, allowing for smooth mechanical installation and management between engineering and onsite machine shop teams to ensure 100% uptime on a $100M+ factory.
- Led field-operator safety initiatives by digitizing documentation and enforcing OSHA-compliant heat and lightning protocols, achieving 100% attendance retention.
Education
B.S. in Mechanical Engineering
Texas A&M University, College Station, TX
- Engineering Project Management Minor
- GPA: 3.64 / 4.00